Showing posts with label arduino. Show all posts

Monday, April 12, 2010

What has already been done

For this project, I plan to create a number of discrete components. At the highest level, they include:
-Interface with GPS
-Interface with a Motor
-Interface with Servo
-Controller for the system

These are all fairly straightforward to build considering many others have interfaced with this hardware set before. This project will really be a task of merging them together, while trying to keep costs low.

Before this blog, I did some initial preparation. This included testing my GPS module with the arduino, and building a basic h-bridge.

This is a photo showing the the GPS module, tied into a breadboard. Also visible is the IC that behaves as an H Bridge. I am using a L293DNE Quad Half-H Driver 16 dip IC. This part can drive my motor at up to 0.6A of current. Ideally I would have a 1A or 2A unit, but I am trying to use existing parts. This might be an issue down the road :)

Shown here is a photograph of the constructed H-Bridge. I could drive two motors off this IC, but will only require one.


And Finally everything tied together (with nice jumper wires! purchased because they make everything look so nice). This is 90% of the final hardware - the only parts missing are a servo, and motor.


Finally - this is a testing environment for in my apartment. I have the arduino with GPS unit and bread board in the window to pick up a good signal.


The Idea

I want to create a GPS Way-point driven remote controlled car.

Not too long ago I woke up one morning and thought of attempting this project. I knew that it was possible to interface an Arduino micro-controller with readily available GPS modules. I also knew that it would certainly be possible to interface the Arduino with an RC car.

The plan would be to use a basic feedback loop to control the direction of the car. At it's heart the logic of the microcontroller would be:
1) Where am I?
2) Where was I 1-2 second ago?
3) Where do I want to go?
4) According to where I am, and where I was - how does my course need to be adjusted?
5) Adjust steering, move forward, jump to step 1.

This is fairly simple logic, and I think it should be possible. There are a list of unknowns that could ruin this project:
-Accuracy of the GPS unit: some are accurate to 5m or ~16 feet! That's likely going to send the car into some curbs.
-The RC-Car platform: not wanting to spend much money means a cheap RC Car! This means steering will likely be terrible, no suspension, small wheels, minimal clearance, etc. etc.
-Others I haven't encountered yet.

So basically, I am going to try and tackle this project in just under two weeks.

As of today - I have a list of parts ordered, and have begun some initial work. I tore apart the RC Car, and begun planning other components of the project.

Posts to come will include:
-Parts list / detailed plan-of-attack
-Construction of an H-Bridge to control the RC Car's drive.
-Retrofitting of a servo to control the steering (rather than a primitive DC motor configuration)
-Interfacing of GPS unit
-Writing a drive algorithm

Finally - it might be worth mentioning that this is my first blog. Additionally I am a Computer Engineering student, so please be friendly regarding grammar, etc.

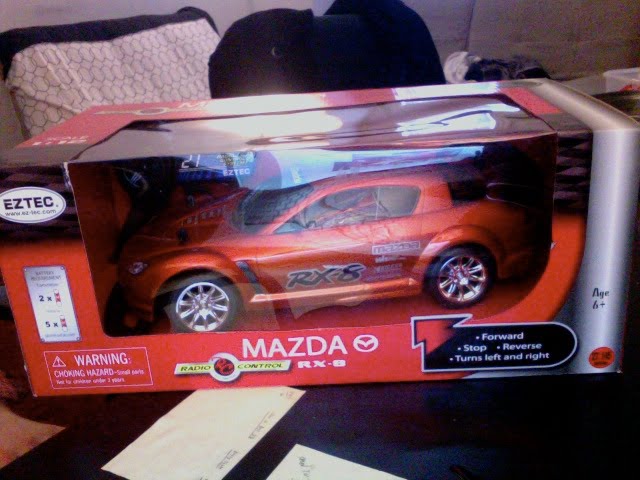
Here are some photos of the car / arduino. Hopefully I get better at including in-line images in future posts!